Oversize Rock Detection AI
Find and size boulders in the haul truck bed, the dump pocket, and on the grizzly before they bridge the crusher.
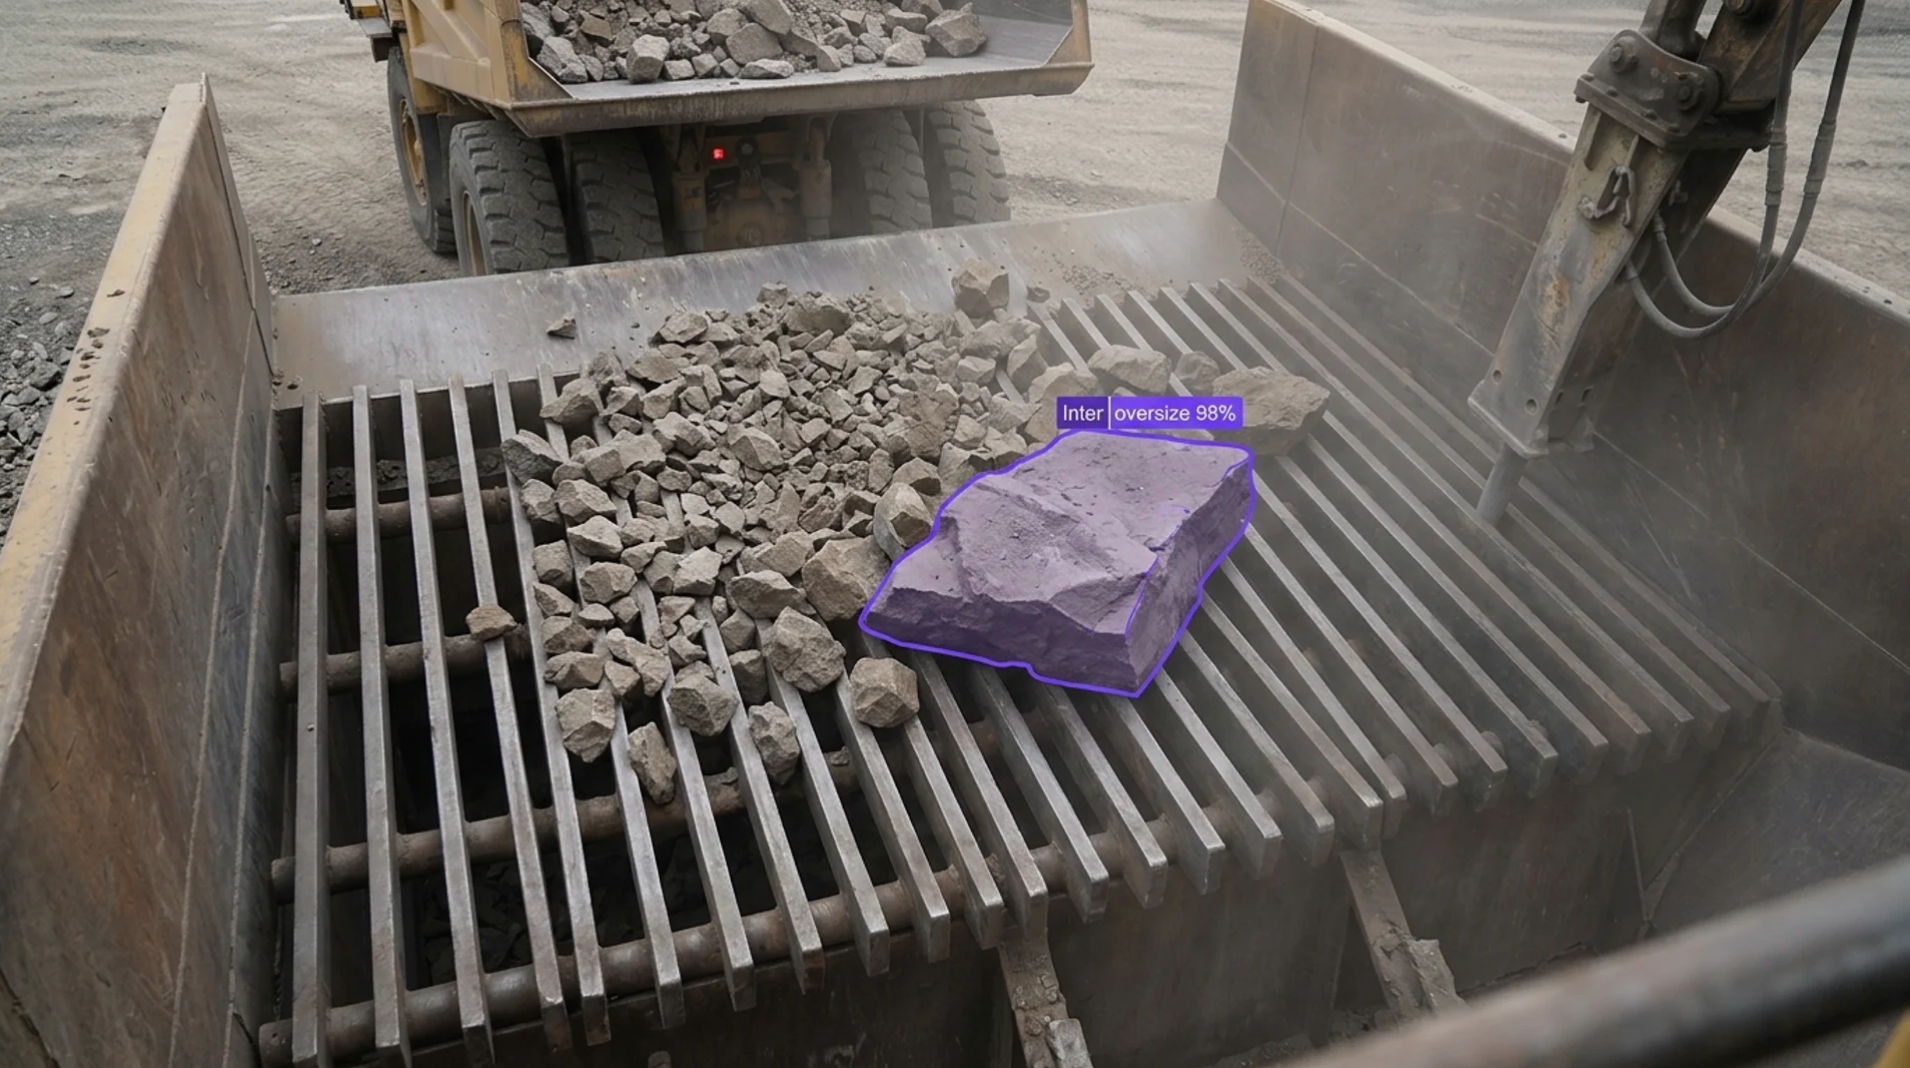
Oversize Rock Detection AI for the Toughest Mine, Quarry, and Primary Crushing Operations
Deploy Anywhere, Run Everywhere
Run oversize rock detection on dump pocket, grizzly, and haul road cameras on the edge, on-prem, in your VPC, or via API, in dust, rain, and night shift lighting.
One Platform, Full Adoption
Tools every mine and plant team can adopt, from drill and blast engineers to crusher operators and processing plant metallurgists, no separate ML team required.
Secure, Compliant, and Audit-Ready
Data stays safe with SOC 2 Type II compliance, encrypted data, HIPAA compliance, and an uptime SLA, with event records that support MSHA 30 CFR Part 56 and 57 safety programs and ISO 45001.
- Boulder Detection in the Dump Pocket
- Rock Size Estimation on the Grizzly
- Oversize in the Haul Truck Bed Before Tipping
- Bridging & Blockage at the Crusher Throat
- Rock Breaker Operator Alerts
- Oversize Rate by Blast, Bench & Shovel
“Roboflow has been instrumental in accelerating our deployment of innovative AI solutions.”
Travis Turnbull
Vice President & CIO, Pella Corporation
Talk to a Vision AI engineer who's shipped in mining and aggregates.
Bring us your toughest oversize rock detection problem and we'll map a working solution.
Ask us about:
- Solution architecture that fits MSHA 30 CFR Part 56 and 57, ISO 45001, and your rock breaker and crusher control setup
- A live demo on your own dump pocket, grizzly, or haul truck footage
- Deployment options: edge, on-prem, air-gapped, VPC, or on dust-rated cameras and NVIDIA Jetson hardware at the primary crusher
- ROI modeling against crusher downtime, rock breaker hours, secondary blasting, and throughput lost to bridging
Over 16,000 organizations build with Roboflow.
- Rivian
- Pella
- Chobani
- USG Corporation
- BNSF Railway
- American Woodmark
Vision AI is transforming businesses
Customers across the board are solving complex challenges and driving meaningful impact.
- Automotive customer
$10 million
Saved by automatically detecting defects on the production line
- Logistics & freight company
90%
Less time spent manually tracking shipping inventory
- Building materials supplier
60%
Lower customer return rate with improved product quality
Catch Oversize Before It Bridges the Crusher, from the Haul Truck to the Primary Feed
Bring real-time intelligence to every load that reaches the primary crusher with Roboflow Vision AI for oversize rock detection.
See oversize before and after the truck tips:
- Detect and estimate the size of boulders in the haul truck bed as it backs up to the dump pocket, with a model trained on your own ore, lighting, and dust.
- Find oversize on the grizzly and in the dump pocket, and separate a true boulder from a pile of fines that only looks large at that angle.
- Flag a slab or boulder that is likely to bridge the crusher throat based on its size and orientation, not just its presence.
Direct the rock breaker and protect the crusher:
- Alert the rock breaker operator with the rock marked on screen, so the right rock is broken first.
- Watch the crusher throat for bridging and blockage and warn the control room before the feed stops.
- Send a hold signal to the apron feeder or dump pocket traffic light through the PLC when oversize is waiting to be broken.
Feed the blast team the data:
- Log oversize events with a clip, truck ID, and timestamp so each boulder ties back to a shovel, bench, and blast.
- Report oversize rate per blast and bench so drill and blast engineers can tune burden, spacing, and powder factor.
- Pair with rock fragmentation analysis on the same cameras to see the full size distribution, not only the boulders.
Bring intelligence to every load at the dump pocket today. Stop oversize rock from becoming a bridged crusher, a stopped plant, and extra rock breaker hours.
Frequently asked questions
What is oversize rock detection with Vision AI?
Oversize rock detection with Vision AI uses cameras over the haul truck bed, dump pocket, and grizzly and a trained computer vision model to find boulders and slabs too large for the primary crusher, estimate their size, and alert the rock breaker operator or hold the feed. Events are logged with a clip and tied to the truck, shovel, and blast. It pairs with rock fragmentation analysis, conveyor belt monitoring, and haul truck detection across computer vision in mining.
Can Vision AI estimate rock size from a single camera?
Yes, a segmentation model outlines each rock, and a camera calibrated to a known reference (the grizzly bar spacing, a truck bed, or a marker) converts the outline to an approximate size.
Does oversize rock detection support MSHA and ISO 45001 programs?
Oversize rock detection supports the safety expectations of MSHA 30 CFR Part 56 and 57 (the US safety and health standards for surface and underground metal and nonmetal mines) and ISO 45001 (the occupational health and safety management system standard) by reducing manual interventions at the dump pocket and crusher, and by keeping a record of every event.
Roboflow serves as the detection engine, and your plant, maintenance, and safety teams own the rock breaker procedures, the feed hold logic, and how the crusher control responds.
Can it integrate with our crusher controls, fleet management, and SCADA?
Yes. Roboflow writes oversize and bridging events to a PLC tag over OPC UA, Modbus TCP, or MQTT, so Allen-Bradley, Siemens, and ABB controllers can hold the apron feeder or set the dump pocket light. Events and clips can be sent over REST or written to a database for SCADA and historians such as Ignition and AVEVA PI, and matched to truck and shovel IDs from fleet management systems such as Modular Mining, Hexagon, and Caterpillar MineStar.